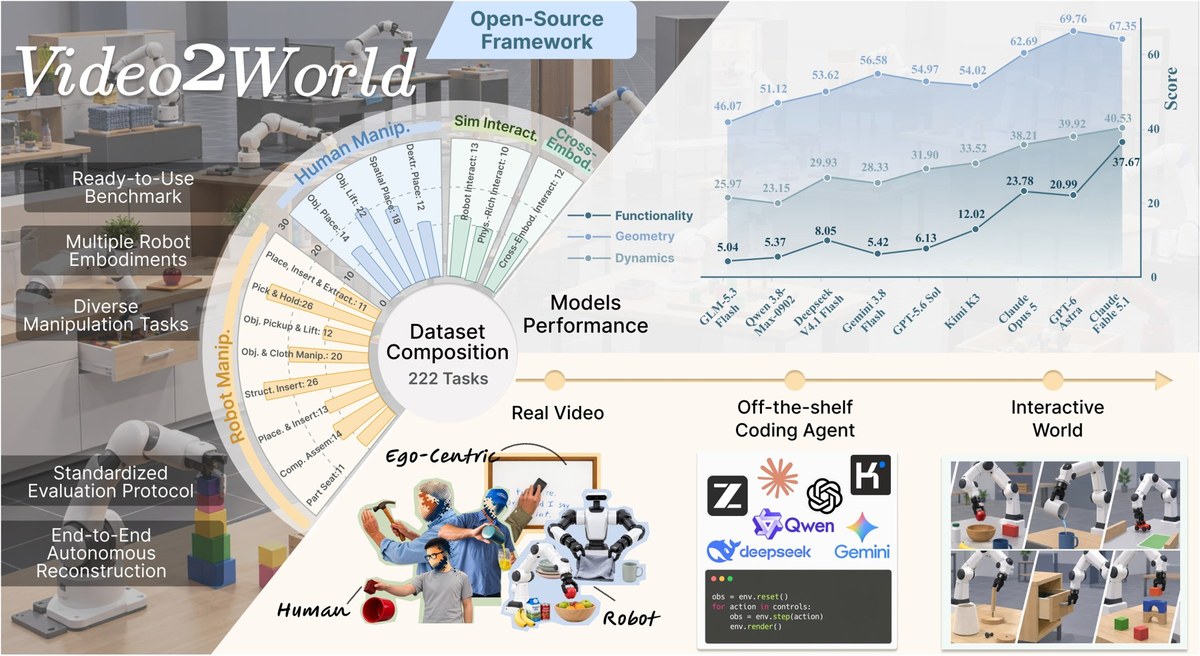
A benchmark that frames autonomous video-to-simulation as a software engineering task: coding agents watch an embodied video, build the simulated environment and robot behavior, and refine them through execution feedback. 222 reconstruction instances across 39 task families, scored on geometric fidelity, dynamic fidelity and functional correctness.
Publications

A self-improving framework (World Action Verifier) that decomposes action-conditioned prediction into state plausibility and action reachability, exploiting forward–inverse asymmetry for verification and data-efficient world-model learning.


A multi-agent framework that models agentic workflows as self-organized graphs and co-evolves agent semantics and collaboration topology via the Semantic-Topological Evolution (STEV) algorithm.
